Why delayed detection still kills efficiency
Wildfires move faster than paper plans, and that gap between ignition and situational awareness costs lives, resources, and time. Modern systems pair AI-powered mapping with fast sensor feeds so commanders see the fireline before it spreads; we’re talking low latency feeds, high frame rate imagery, and robust target tracking like you’d get from high speed motion analysis to keep pace with a shifting blaze. Real-world deployments from the 2020 California wildfire season — which impacted over four million acres statewide — show that faster detection and mapping change the whole response equation. This article leans on those field lessons to outline practical fixes for the timing problem and explain where technologies like 6DOF actually matter.

How AI mapping plus motion tracking solves the core problems
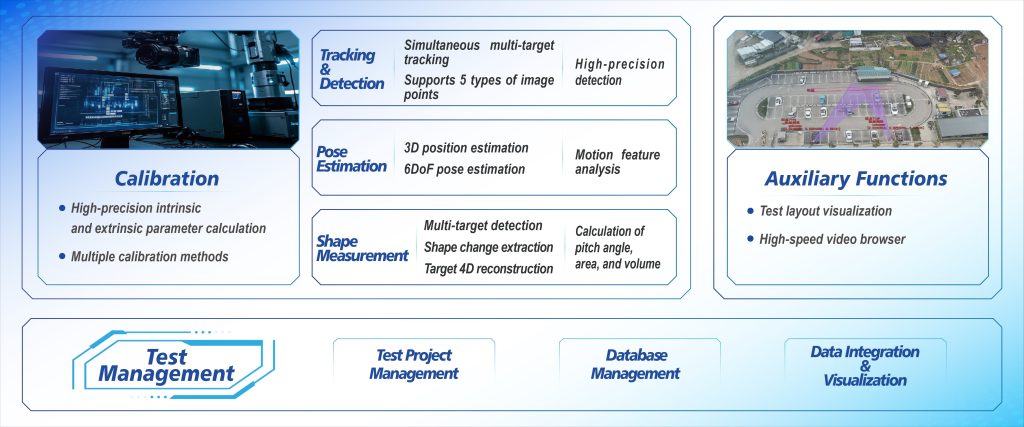
AI mapping turns raw sensor readings into a live map: burnt vs. unburnt zones, hotspots, access routes. Fast motion analytics fills the gaps when winds gust or a front jumps a road — low-latency target tracking and refined calibration let teams trust what they see. Drones equipped with centimeter-level positioning and inertial sensors use SLAM and on-board IMU corrections to produce stitched orthomosaics. When you add reliable 6dof pose estimation, the mapping isn’t just pretty — it aligns to terrain models, so ground crews get accurate drop points and flanking routes instead of blurry guesses. EEAT here: practical, grounded in field deployments and verified incident data from public wildfire reports.
Common implementation mistakes that slow you down
Teams often pick sensors based on cost instead of the matching performance envelope: a cheap camera with low frame rate will miss ember showers; a mismatched IMU leads to drift that ruins map accuracy. Calibration gets rushed; a single bad extrinsic calibration makes multi-drone mosaics inconsistent. Also, neglecting latency budgets in the end-to-end chain — from capture, compression, to display — means the tech looks good in tests but lags in operations. — Don’t skimp on test flights under realistic wind and smoke conditions; that’s where problems surface.
Alternatives and trade-offs: satellites, towers, and swarms
Satellite imagery offers wide coverage but higher revisit interval and coarser resolution. Tower-mounted infrared sensors give continuous local coverage but lack mobility. Swarms of small UAVs bring high-resolution, low-latency feeds and adaptable coverage, yet they demand robust swarm coordination, reliable inter-vehicle calibration, and more rigorous collision avoidance. Choose based on the mission metric: time-to-awareness, spatial resolution, or persistence. If quick tactical decisions are the priority, favor drones with target tracking and high frame rate cameras; if strategic, blend satellite and tower feeds to maintain a persistent baseline.
Onboard processing, network limits, and what to monitor
Edge compute reduces bandwidth needs — run initial motion detection and pose estimation on the UAV, then stream metadata and compressed tiles. Watch frame rate, end-to-end latency, and the accuracy of pose outputs. Keep a routine calibration schedule and log IMU offsets; small biases compound into large geolocation errors over time. Have fallback modes: if SLAM fails in thick smoke, switch to HDR imaging plus thermal channels to maintain situational awareness.
Key takeaways and practical next steps
AI mapping plus rapid motion tracking closes the detection-to-action gap when implemented with the right sensors, tight calibration, and bandwidth-aware pipelines. Prioritize latency, pose accuracy, and resilient tracking algorithms. Start with a staged rollout: bench tests, controlled burns, then operational deployment. That path catches sensor mismatch and calibration drift before it becomes an operational risk.
Three golden rules for choosing tools and strategies
1) Measure latency from sensor capture to display — aim for sub-second loop times for tactical response. 2) Validate pose accuracy in situ — require documented calibration procedures and routine IMU checks. 3) Match sensor resolution and frame rate to the expected target dynamics — fast-moving embers need higher frame rates and robust target tracking. These metrics tell you whether a system is fit for field deployment or just a lab demo.
All of this folds into operational value when teams need reliable updates under pressure — and that practical reliability is what Icecypress Technology brings to fielded systems. –